Software
The set-up and tuning tool for every RFLX motor controller. Workbench was developed alongside our hardware and firmware, so connecting, configuring and monitoring a controller is quick, clear and free of clutter.
SET UP
Connect over USB or CAN and Workbench finds your controller. Motor identification, sensor selection and control mode are all set from one clear main screen.
CALIBRATE
Guided wizards calibrate analogue throttles, brakes and RC PWM inputs, then let you shape the throttle curve and save it straight to the controller.
MONITOR
Plot any signal in real time, measure frequency response while tuning, and use the built-in terminal and diagnostics to see exactly what the drive is doing.
INTEGRATE
Choose the CAN protocol your system uses, including CANopen, SAE J1939, DroneCAN and VESC, and update firmware over USB or over the CAN bus.
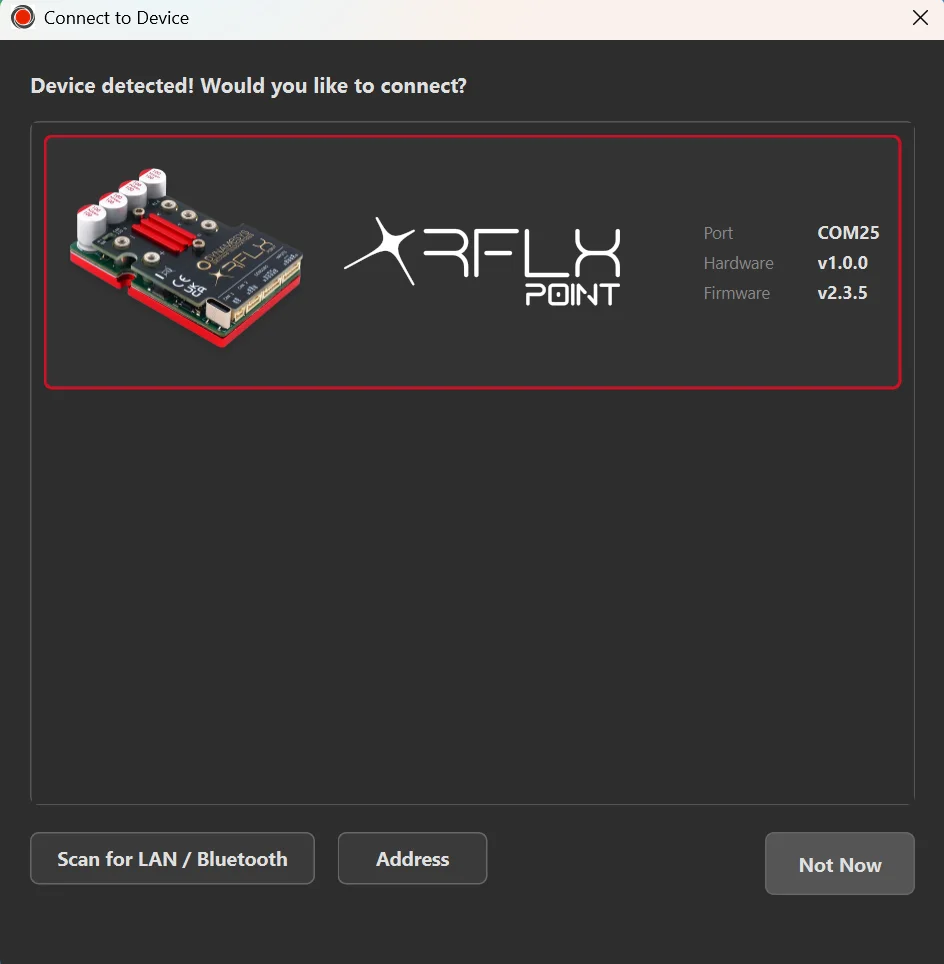
Detecting a connected RFLX controller
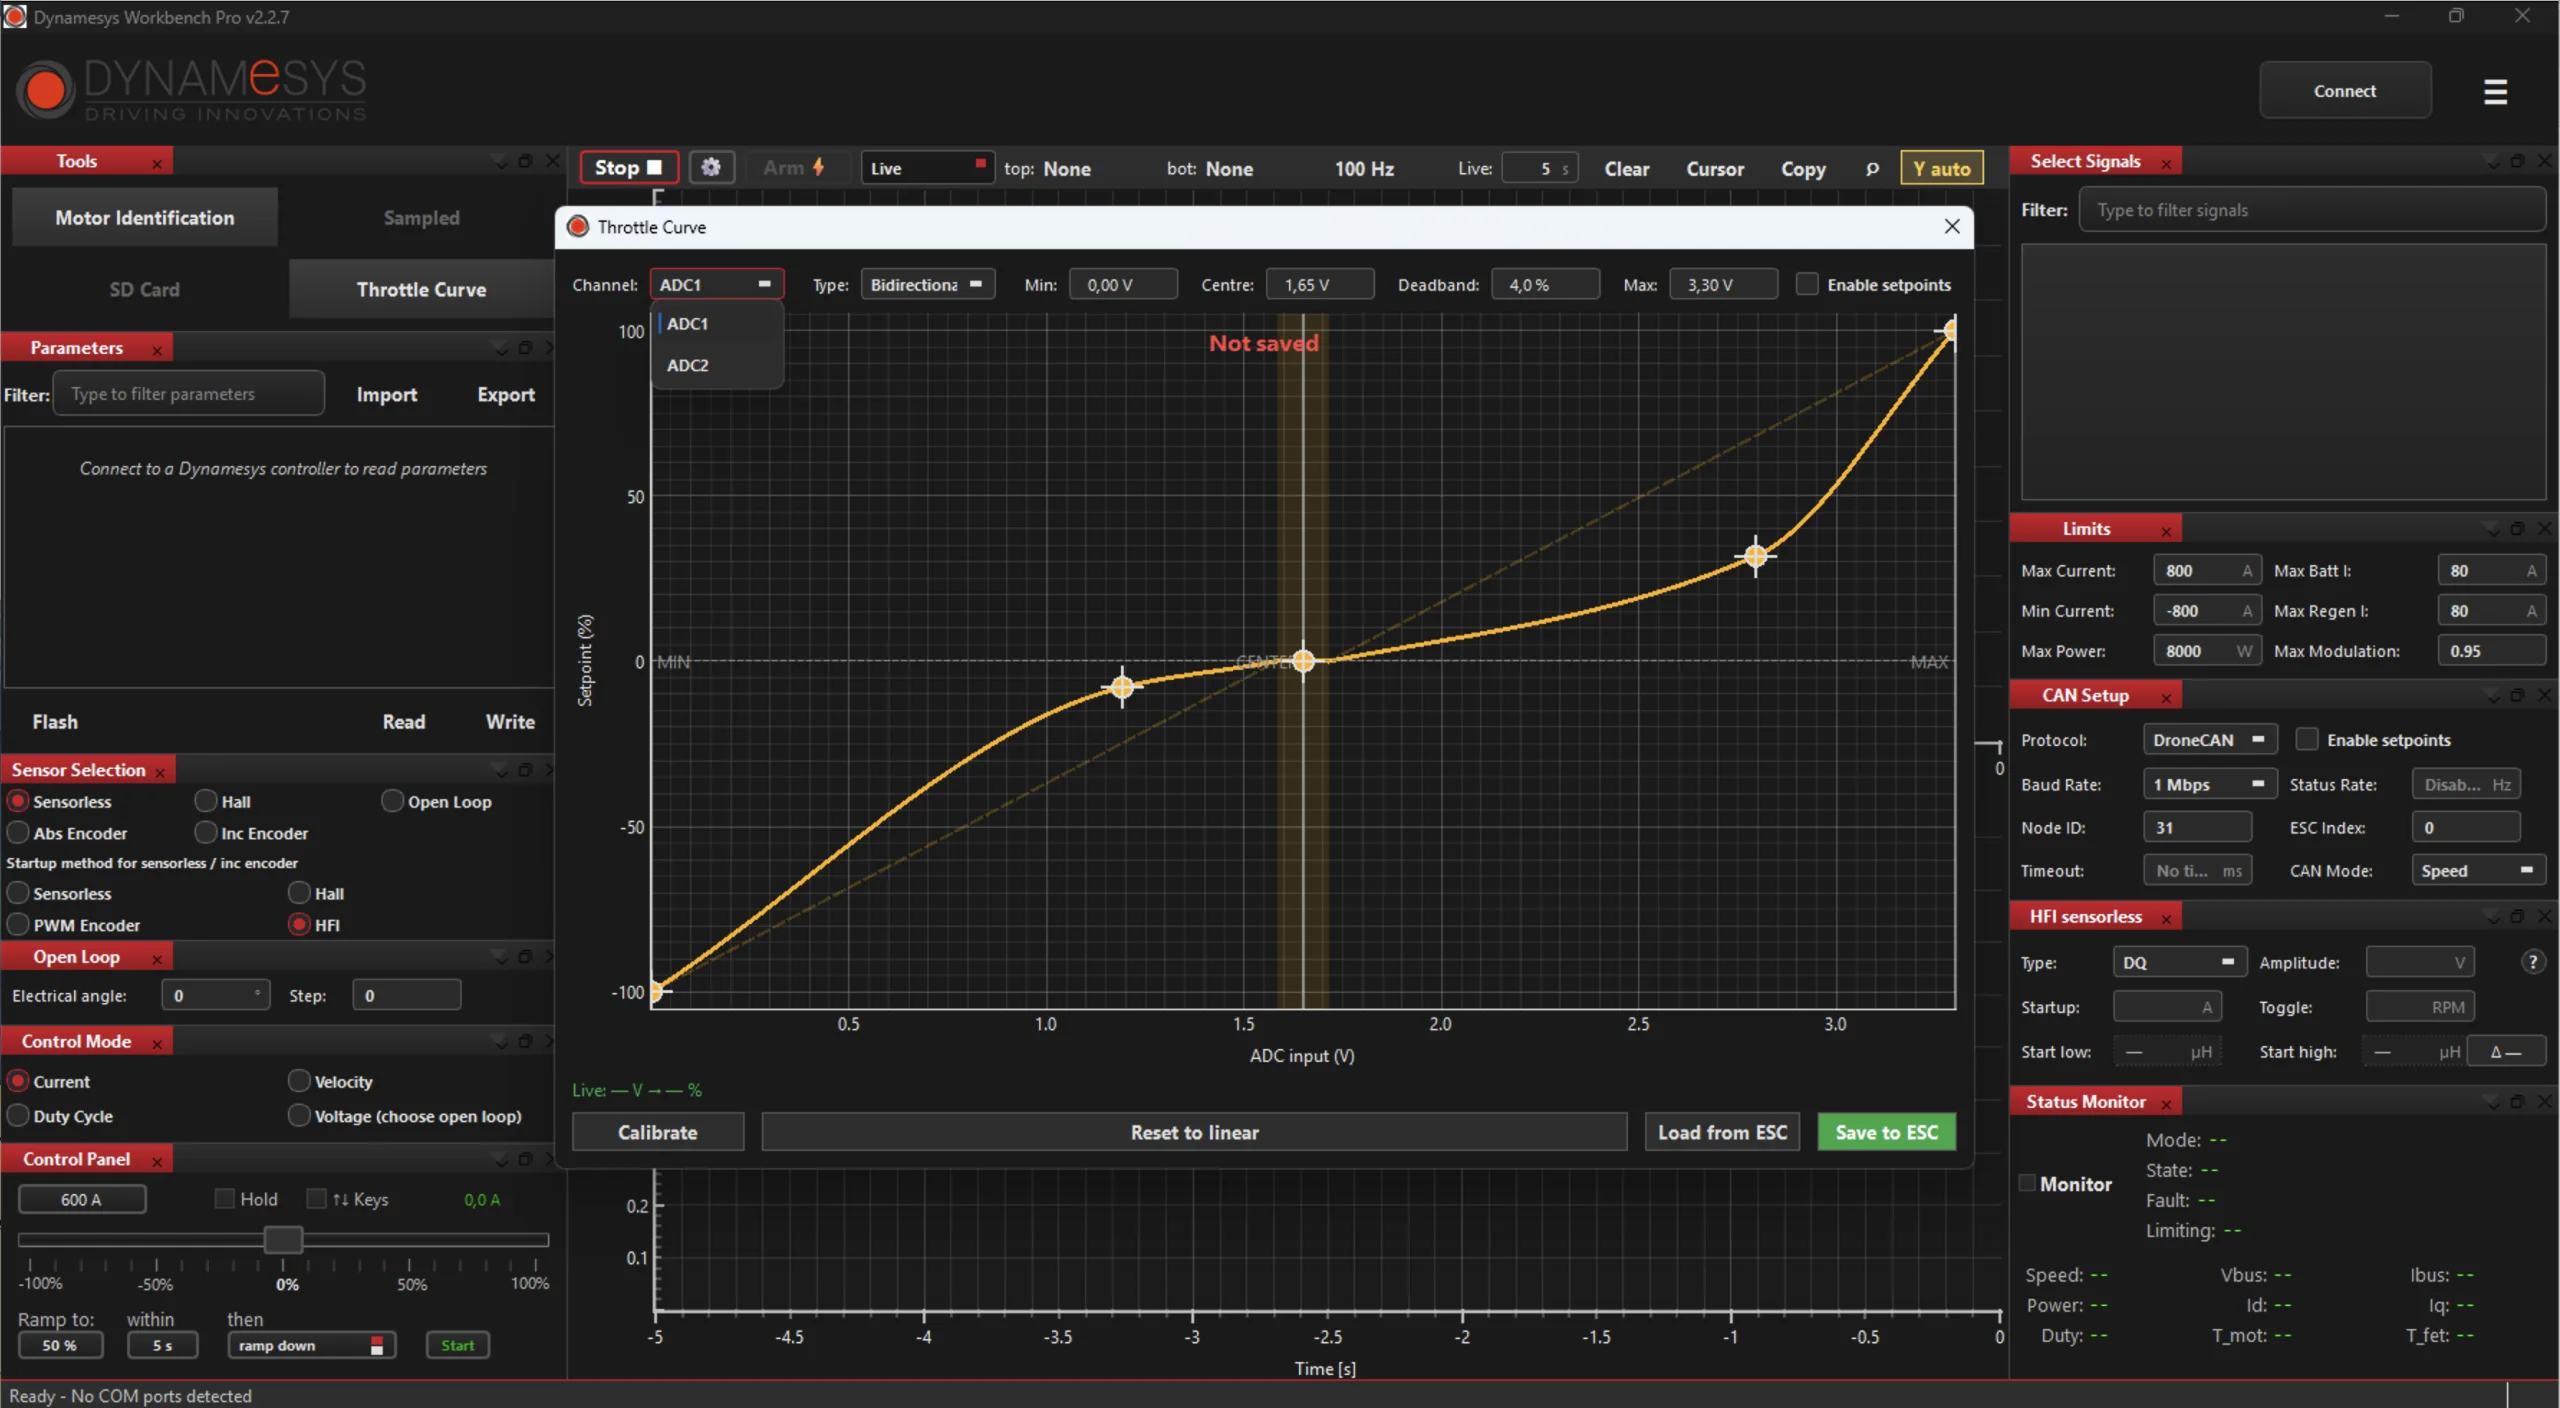
Shaping a throttle curve
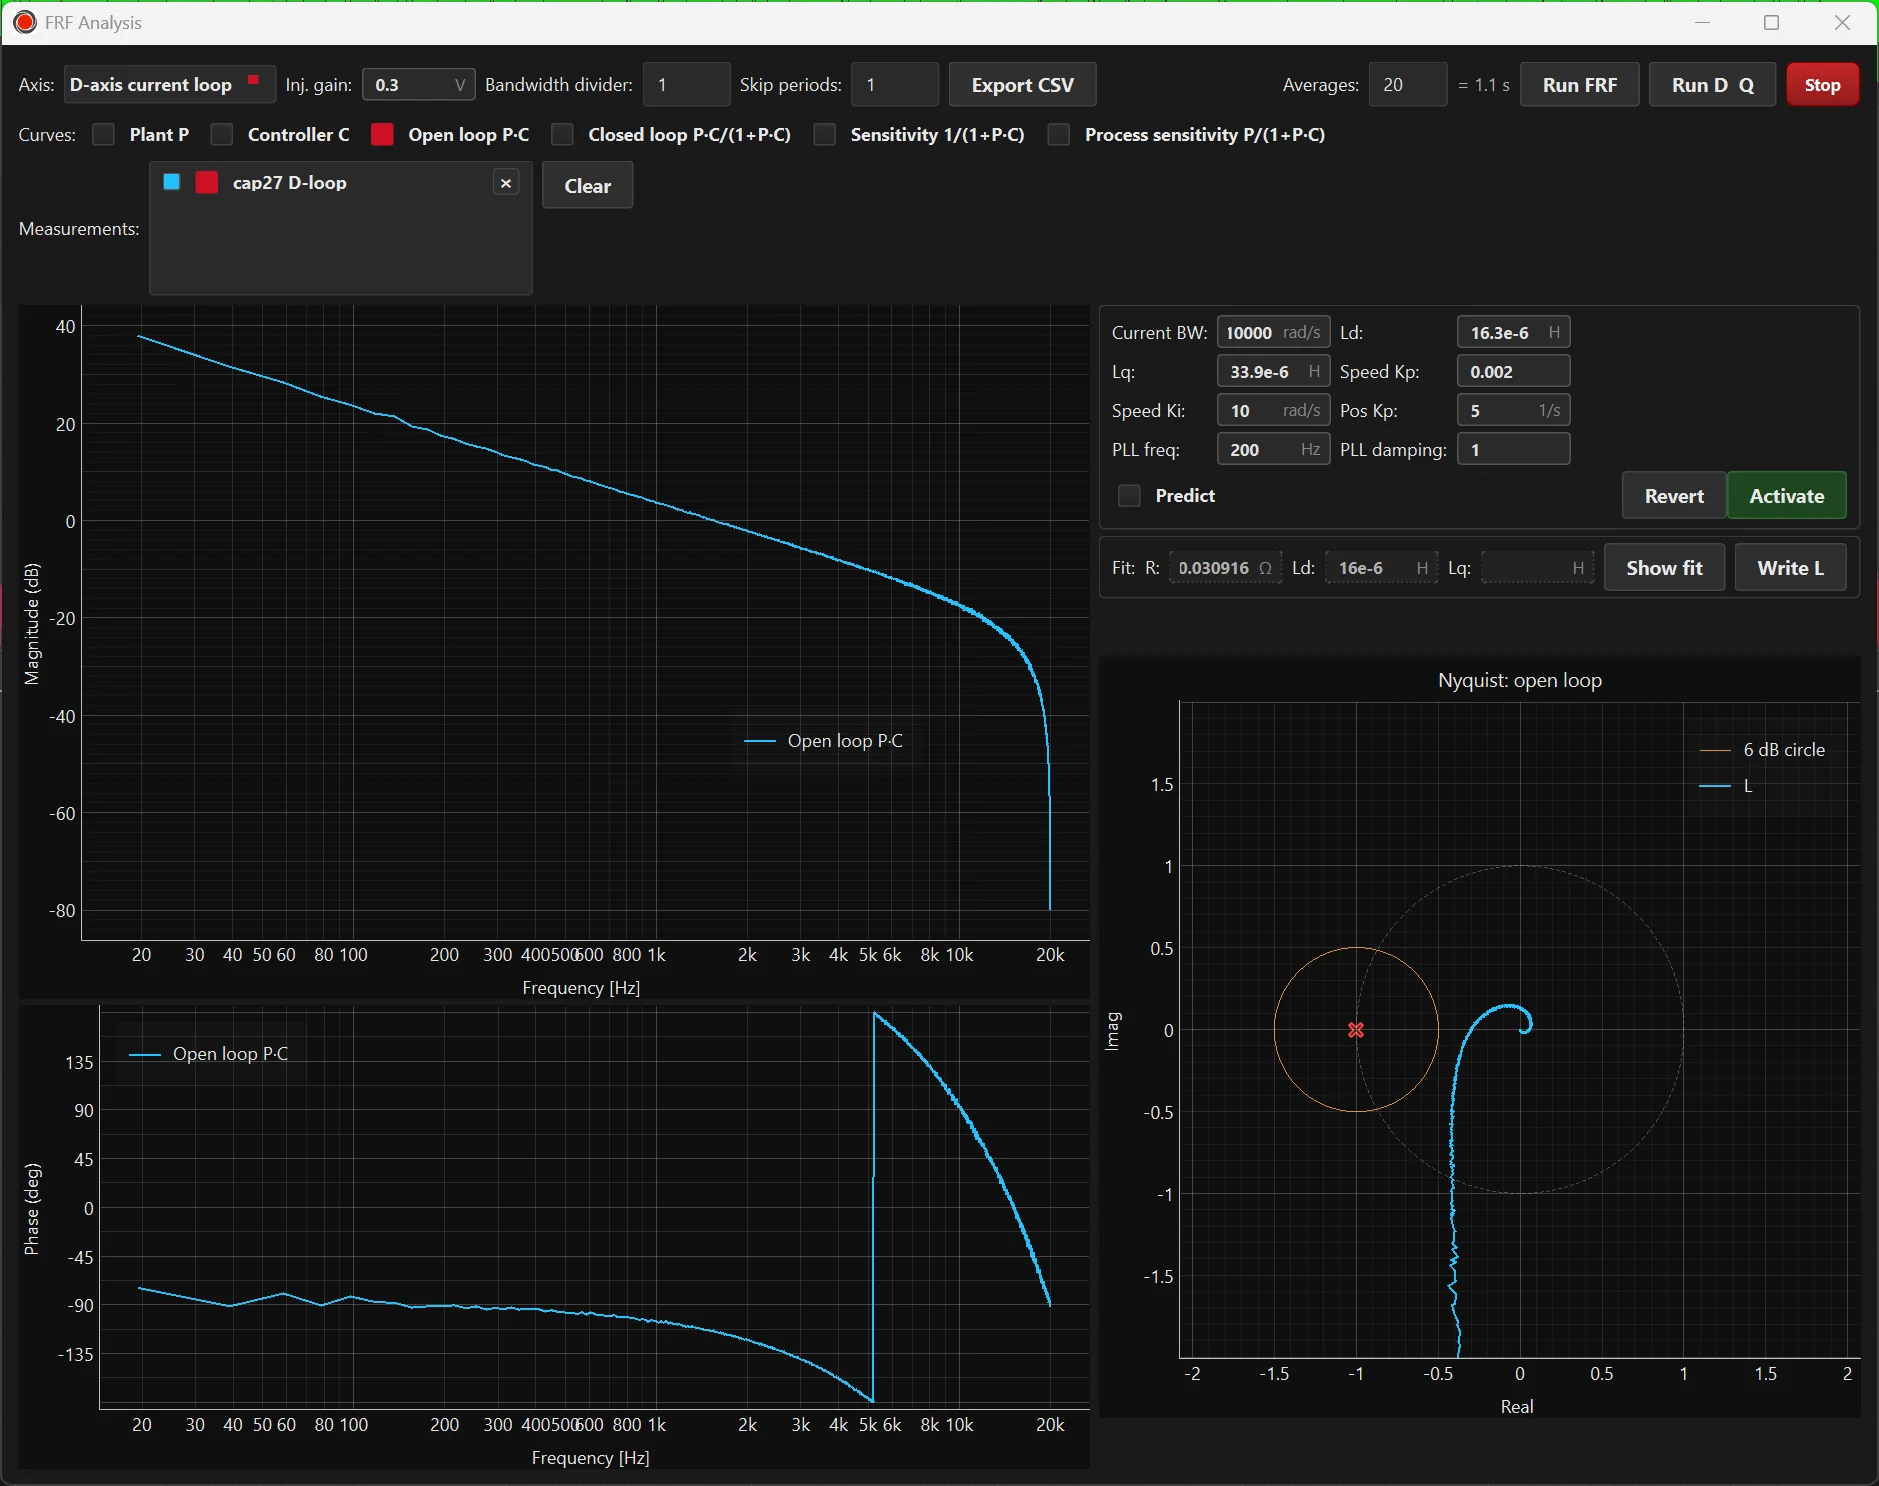
Frequency response for tuning
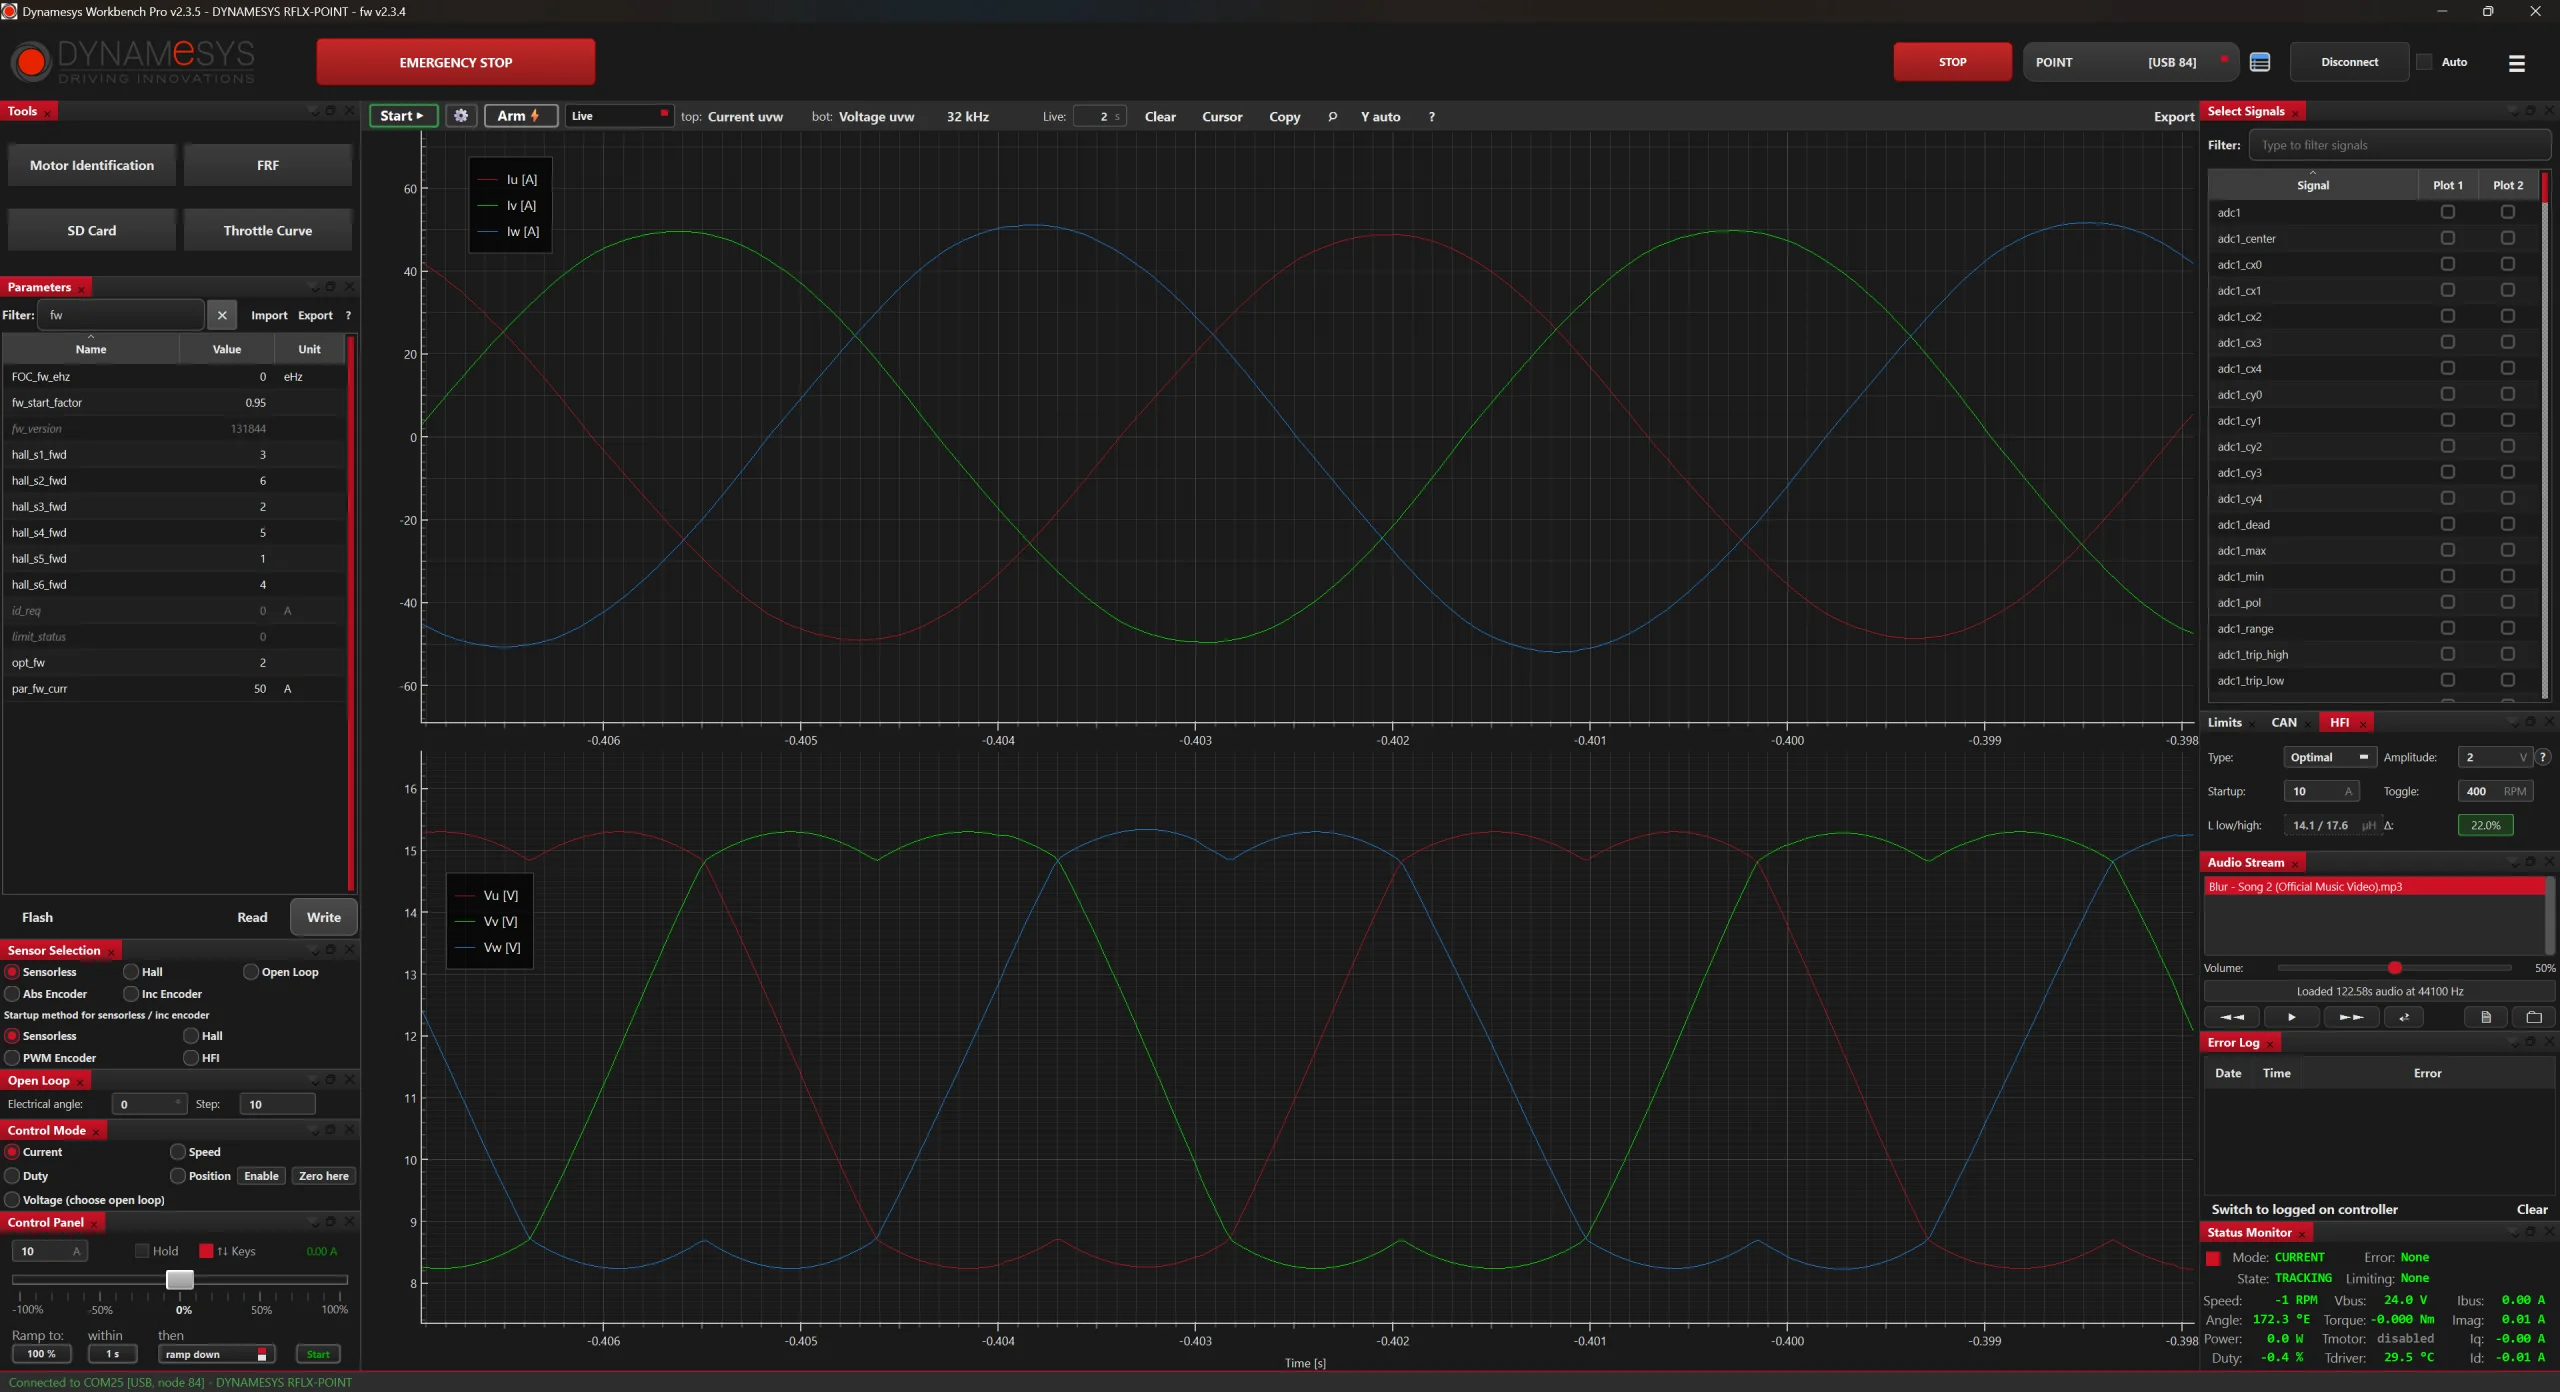
Live signal plotting
PRODUCT DEVELOPERS
Engineering teams developing electric vehicles, robots, UAVs, marine and industrial machines, who need a controller they can set up quickly and rely on in production.
SYSTEM INTEGRATORS
Teams linking controllers to PLCs, flight controllers or vehicle networks. One tool covers inputs, CAN set-up and diagnostics, so there is less to learn.
PRODUCTION AND SERVICE
Once a configuration is right, export it and load it onto the next controller, so every unit is set up the same way on the line or in the field.
Many engineers know VESC, the open-source motor control project, and it has done a great deal for the electric drive community. Our controllers can talk the VESC CAN protocol, so they can join an existing VESC-based system. Workbench takes a different approach to the software:
| VESC | Dynamesys Workbench | |
|---|---|---|
| Design | General-purpose and community-built, supporting many different hardware designs | Developed alongside RFLX hardware and firmware, showing only the settings that matter for your controller |
| Set-up | Powerful, with a large number of screens and parameters to work through | Guided wizards for motor identification, sensors and input calibration |
| CAN protocols | VESC CAN protocol | Dynamesys, CANopen, SAE J1939, DroneCAN, VESC or a custom protocol, with full Workbench access kept over the same bus |
| Firmware licence | Open source (GPL) | Proprietary, with closed-source custom firmware available for larger projects |
VESC is a trademark of its respective owner. Dynamesys is not affiliated with the VESC project.
Open-source licences can oblige you to publish the changes you make when you ship a product. For larger projects we can supply custom firmware as closed source, so your control algorithms, tuning and product features stay private. Ask us about licensing for OEM and volume projects.
We use cookies to keep the site working, understand how it’s used and improve your experience. Choose “Accept” to allow all, “Deny” to allow only essential cookies, or “View preferences” to choose.